
Event Date
Mechanical Intelligence in Flying Insects, Birds and Robots
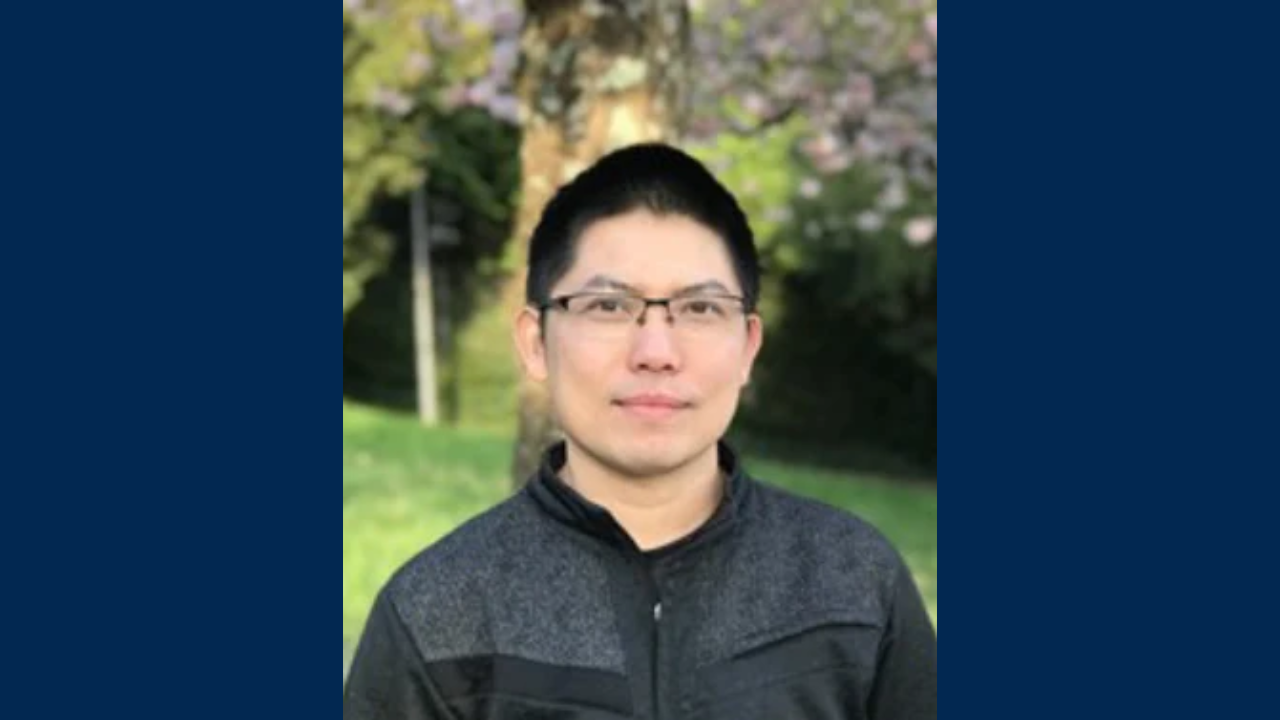
Hoang-Vu Phan, Assistant Professor, University of Nevada, Reno
Abstract
Flying animals exhibit extraordinary levels of maneuverability and agility in environments that are often complex, unstructured, and full of disturbances. Their flight performance usually comes from a combination of sensing, neural processing, muscle control, and the mechanics of their wings and bodies. Yet not every aspect of flight needs to be actively controlled. They can make extensive use of the mechanical properties of their wings, joints, and body structures to simplify control, reduce energetic and actuation demands, respond rapidly to disturbances, and interact safely with the environment. In this talk, I will discuss how birds and insects leverage such mechanical intelligence and how these biological principles can be translated into aerial robotic systems. At the bird scale, I will present avian-inspired drones with morphing wings and tails covered by feather-like structures that can substantially reconfigure their aerodynamic surfaces for agile flight. Inspired by the passive preflexes of avian musculoskeletal wings, I will introduce a spring-latched morphing-wing design that allows drones to absorb in-flight collisions, recover from high-speed wing strikes, and safely traverse tight gaps without active sensing or motor control. At the insect scale, I will present how beetles and flapping robots can deploy and retract their wings without additional actuators and tolerate in-flight wing collisions without damage. I will further present multimodal winged robots with multifunctional legs that can walk, hop over obstacles, and rapidly jump into flight, even using only a single actuator. These examples suggest an alternative approach to design small aerial robots, reducing mechanical and control complexity while improving maneuverability, robustness, and adaptability in challenging environments. Such robots can also serve as physical models for investigating biomechanical principles that are difficult to isolate directly in freely flying animals.
Bio
Hoang-Vu Phan is currently an Assistant Professor in Aerospace Engineering at the University of Nevada, Reno, USA. He received MS and PhD degrees in biomimetics and intelligent microsystems from Konkuk University, Seoul, South Korea in 2012 and 2017, respectively, and BE degree in aerospace engineering from the Vietnam National University, Ho Chi Minh city, Vietnam in 2010. From 2021 to 2025, he was a Senior Postdoctoral Scientist at the Swiss Federal Institute of Technology Lausanne (EPFL), Switzerland. Prior to joining EPFL, he was a non-tenure-track Assistant Professor in the Department of Smart Vehicle Engineering, Konkuk University, Seoul, Korea (2017-2021). His research interests include biologically inspired aerial robotics, flapping and morphing wing flight, multimodal locomotion, and biomechanics of flight. He has published one book and more than 30 papers in prestigious journals across various disciplines including Nature, Science, and Science Robotics. Dr. Phan currently serves on the editorial boards of npj Robotics (Nature Portfolio), and Aerospace.